About

Research Interests and Background

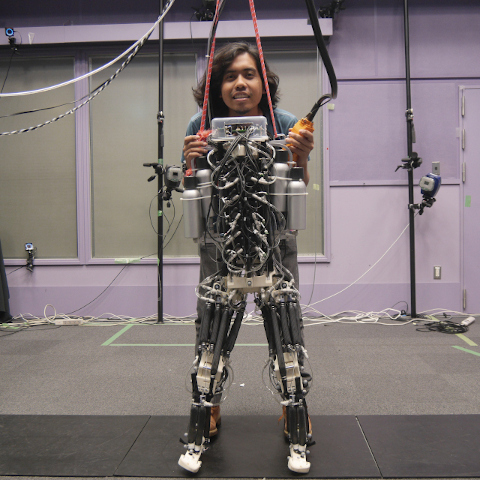
Dwindra with musculoskeletal robot

I have wanted to build robots since I was a kid, humanoids most of all. I picture a future of human-robot coexistence where robots are as convenient and accessible as smartphones are today, and that goal drives my work in robotics.

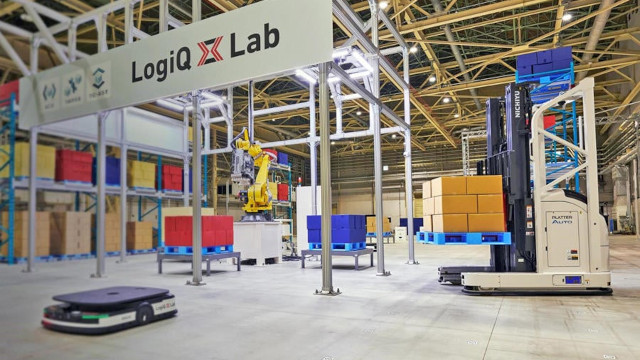
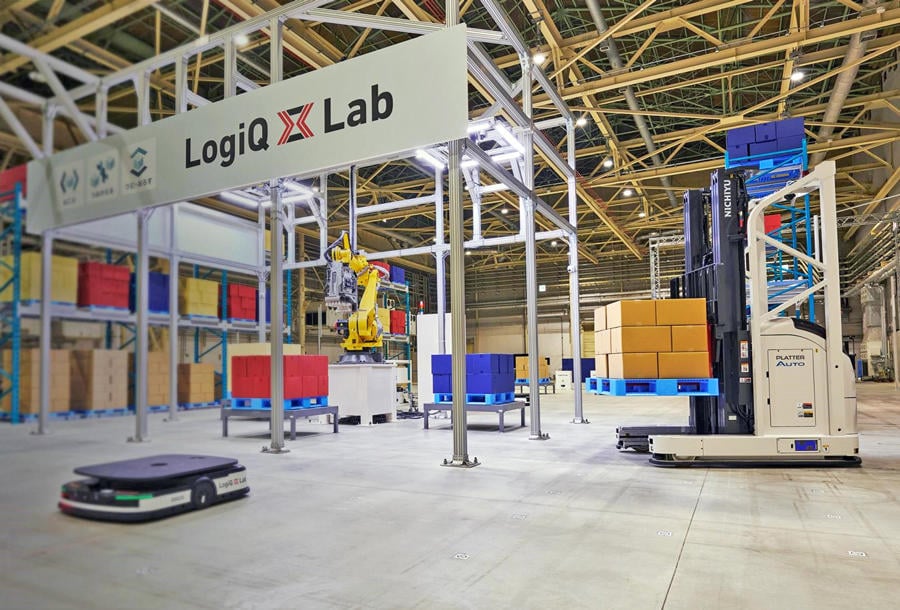
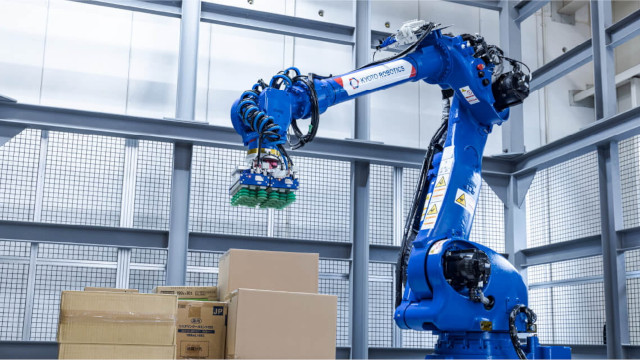
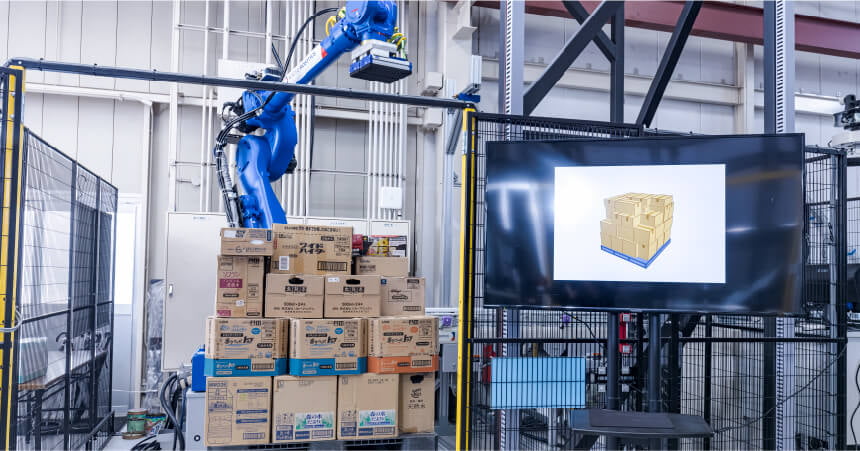
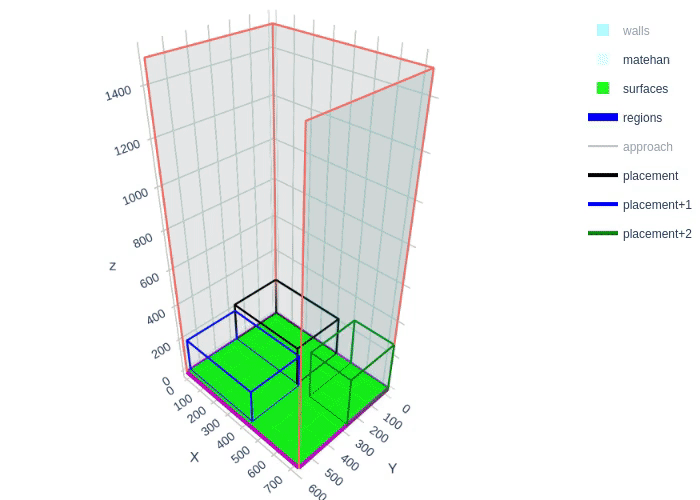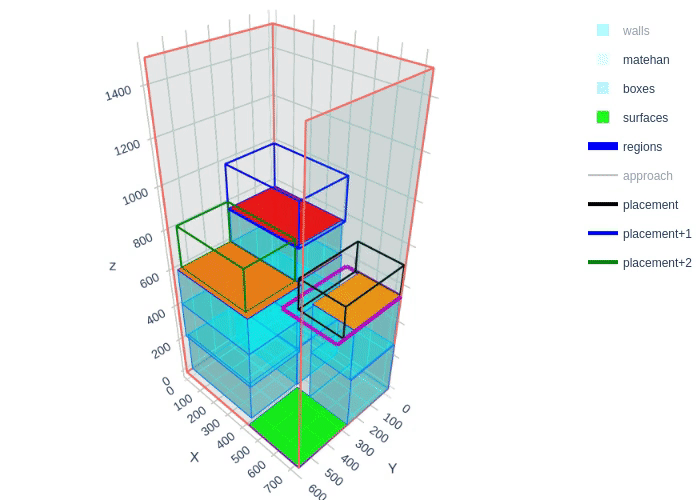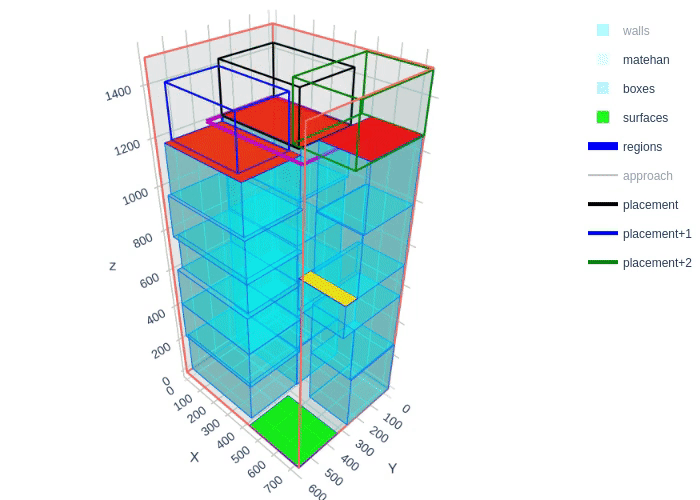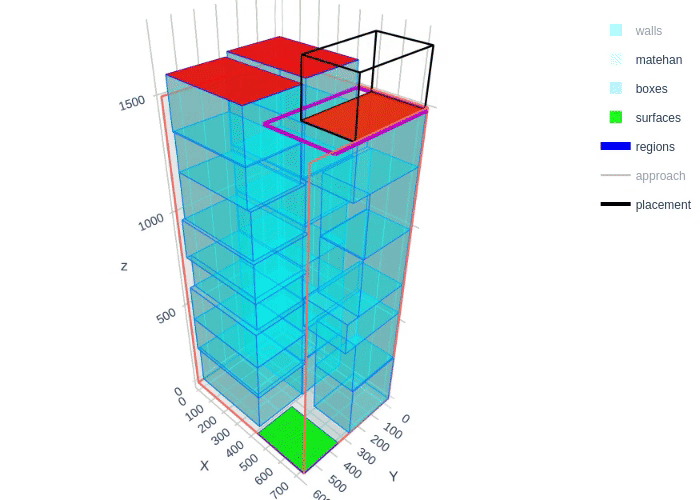
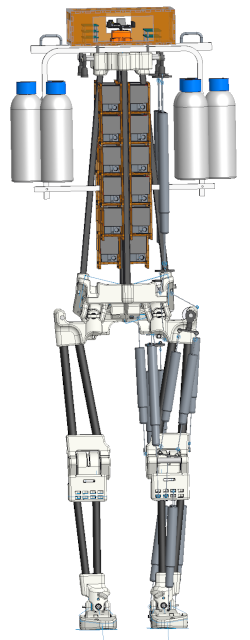
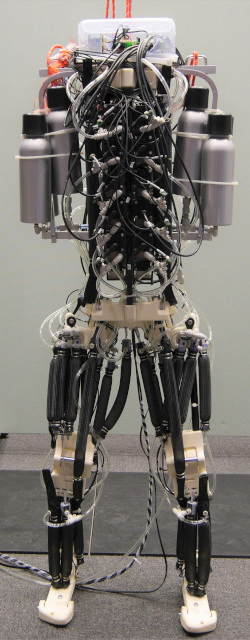
I am a robotics engineer with a B.Sc. in Electrical Engineering from Institut Teknologi Bandung and an M.Sc. in Mechano-Informatics from The University of Tokyo. During my Master's research, I worked on a bio-inspired humanoid robot using pneumatic artificial muscles for agile, explosive movements. Since then, I have gained professional experience in industrial robotics, particularly robot motion planning control, and palletizing systems for logistics automation.

I want to keep deepening my research in robotics and intelligent systems, working toward a future where robots play an integral role in our daily lives.

  • 2023 - now Senior Robotics Engineer, Kyoto Robotics Division, Hitachi Automation, Ltd.
  • 2019 - 2023 Robotics Engineer, Kyoto Robotics Corporation (acquired by Hitachi Automation)
  • 2018 M.Sc. in Mechano-Informatics, The University of Tokyo (Intelligent Systems and Informatics Laboratory)
  • 2014 B.Sc. in Electrical Engineering, Institut Teknologi Bandung

Publications

Conference Papers

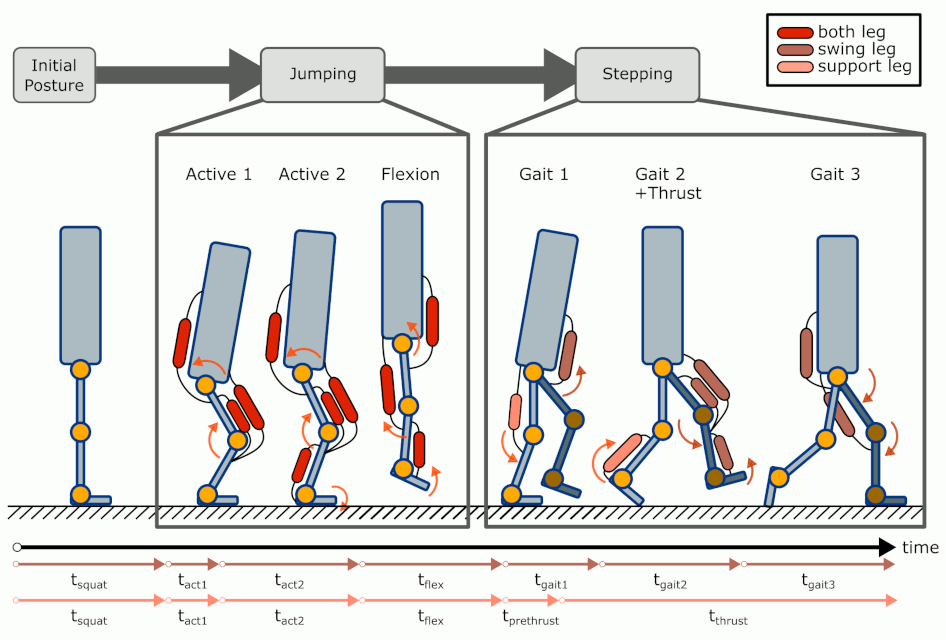
  1. D. Sulistyoutomo, S. Nishikawa, R. Niiyama, and Y. Kuniyoshi, "Sequential Jumping-Stepping Motion on Musculoskeletal Humanoid Robot for Agile Locomotion," Proc. IEEE International Conference on Robotics and Biomimetics (ROBIO), 2018. [IEEE Xplore] [Project]
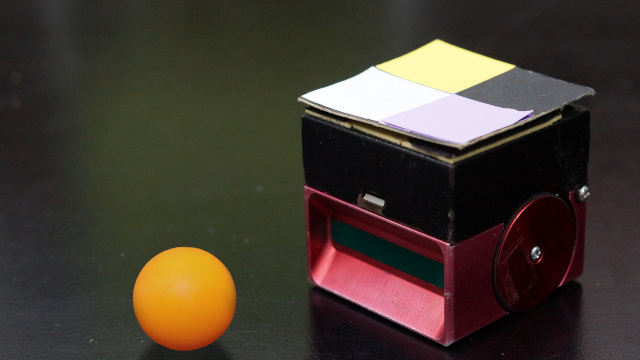
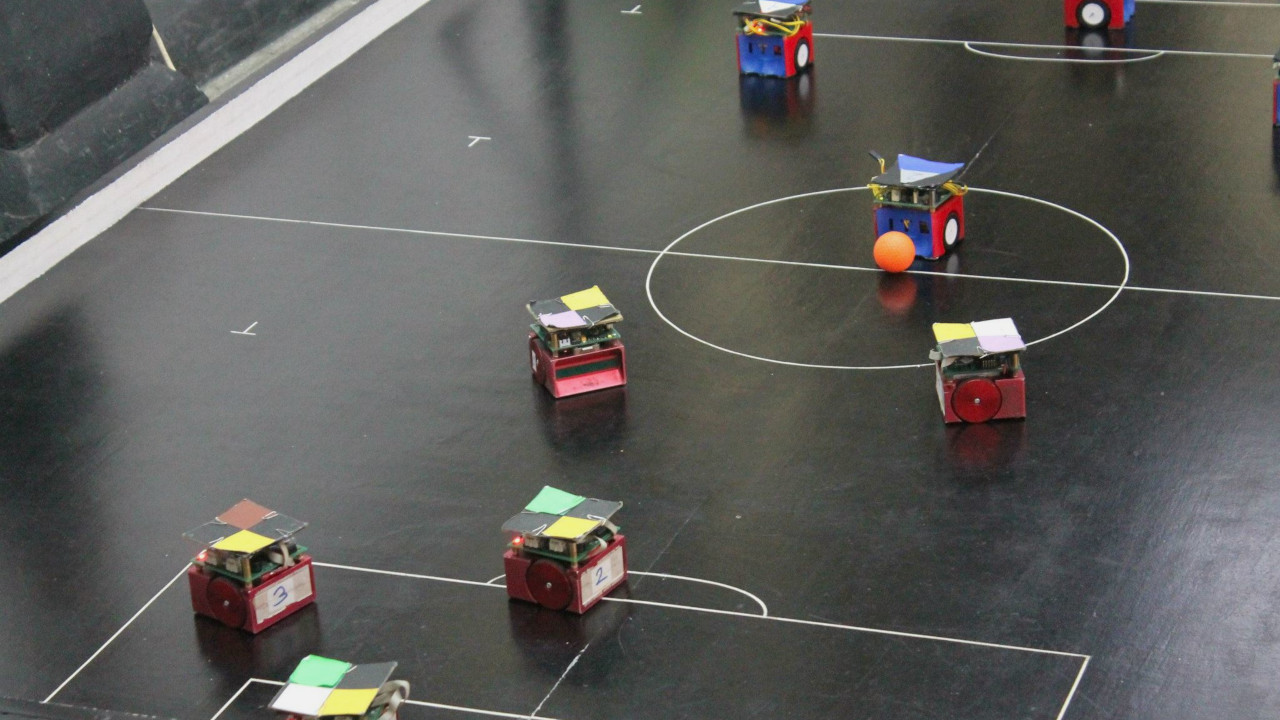
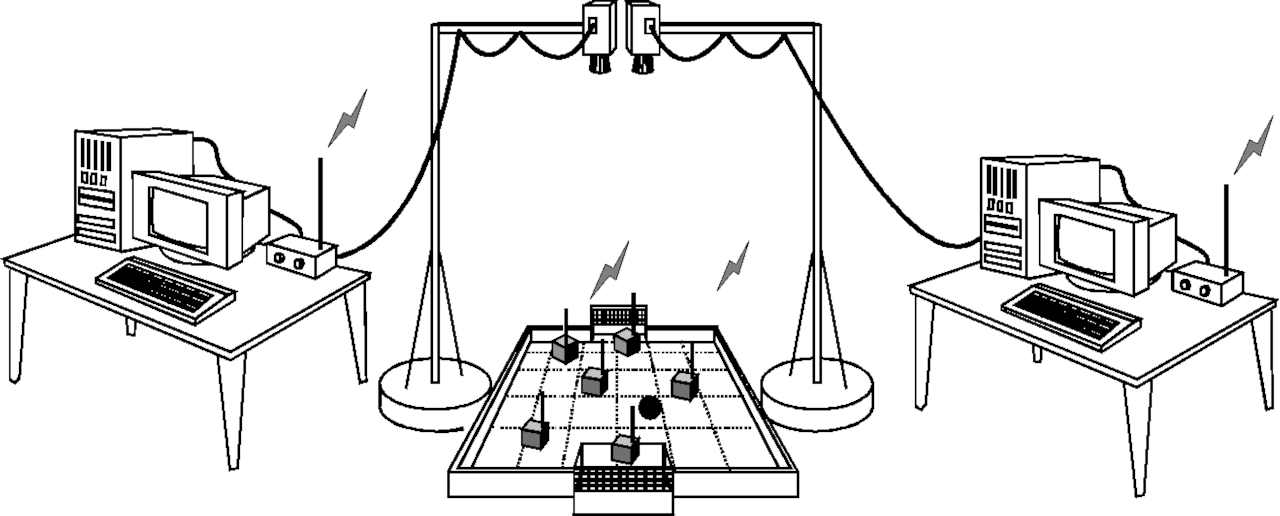
  2. D. Sulistyoutomo, and A. S. Rohman, "PI Anti-Windup Speed Control System for DC Motor in Robosoccer Small-Size League," Proc. Tokyo Tech Indonesian Commitment Award (TICA), 2014.

Patents

  1. Á. K. Vonderviszt, D. Sulistyoutomo, and T. Ishida, "Workpiece Stacking System," Japanese Patent No. 7387931, Nov. 28, 2023. [J-PlatPat]

Portfolio

Selected Projects

Automated Picking Solution

Solution for manual labor dependency

MHI Automated Picking Solution
Palletizing Robot

Intelligent automation solutions for logistics

KRC Palletizing Robot
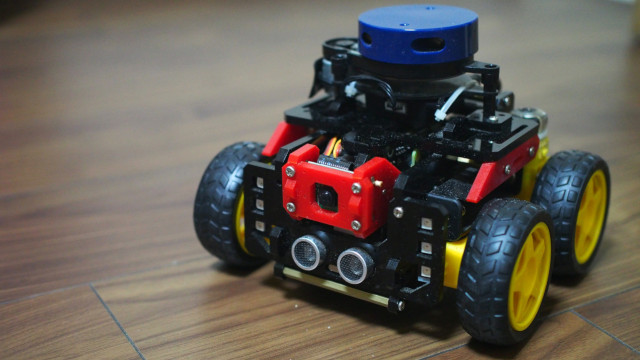
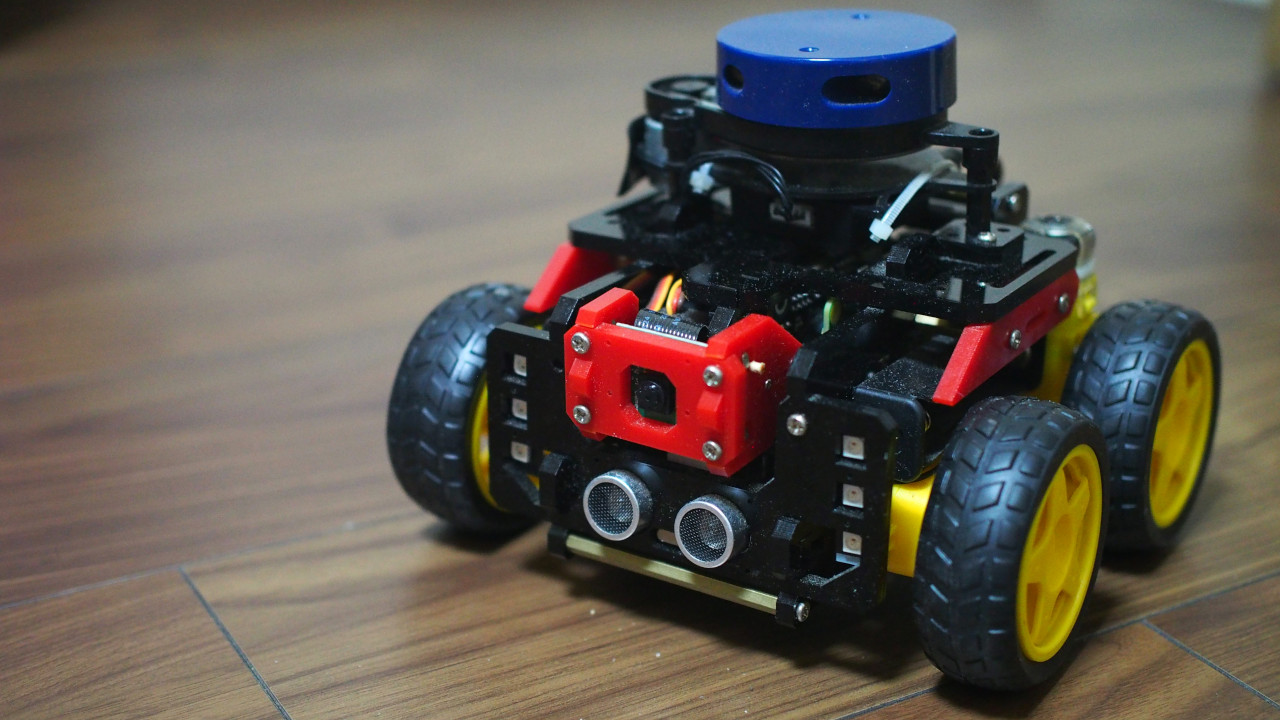
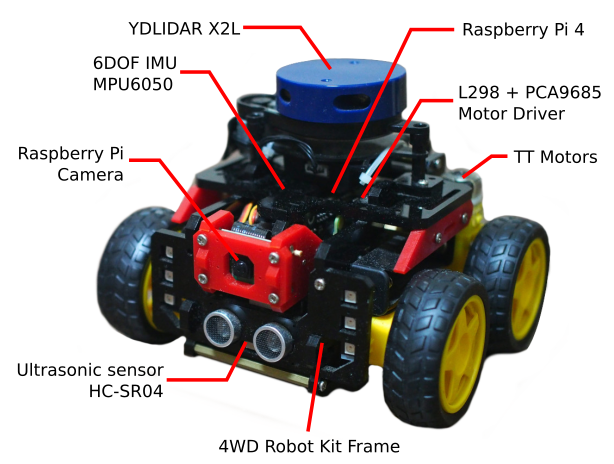
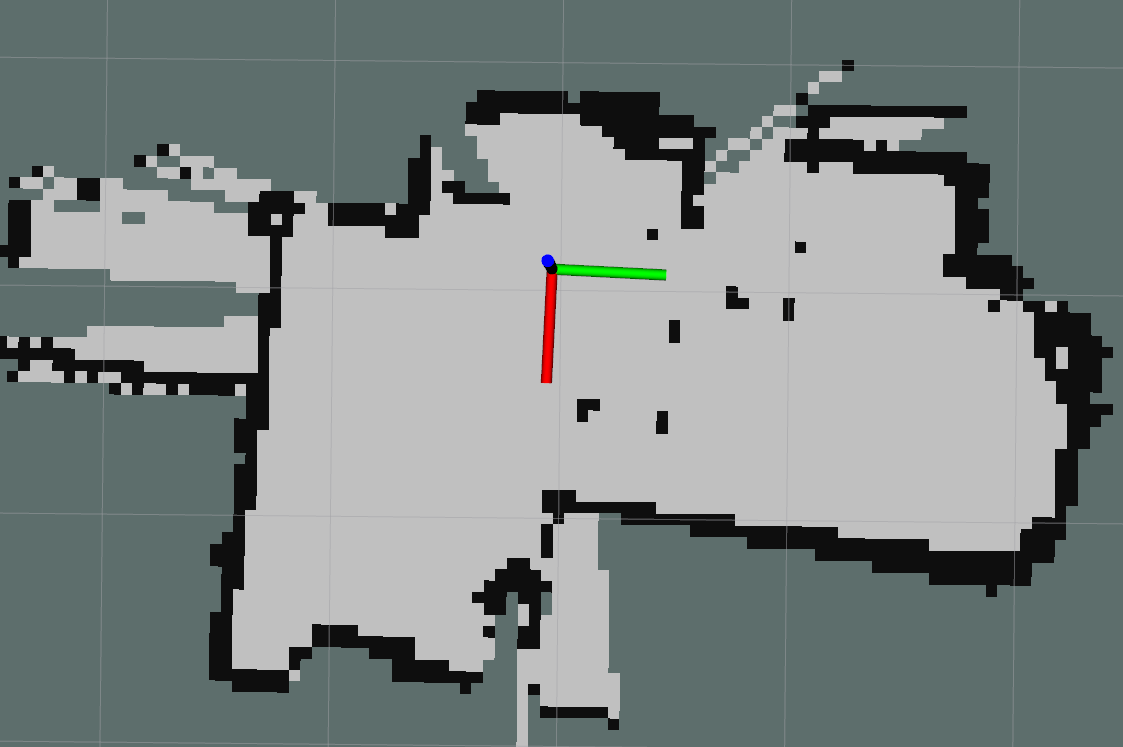
Mini SLAM Robot

Small, powerful, low-cost SLAM robot with ROS support

Mini SLAM robot
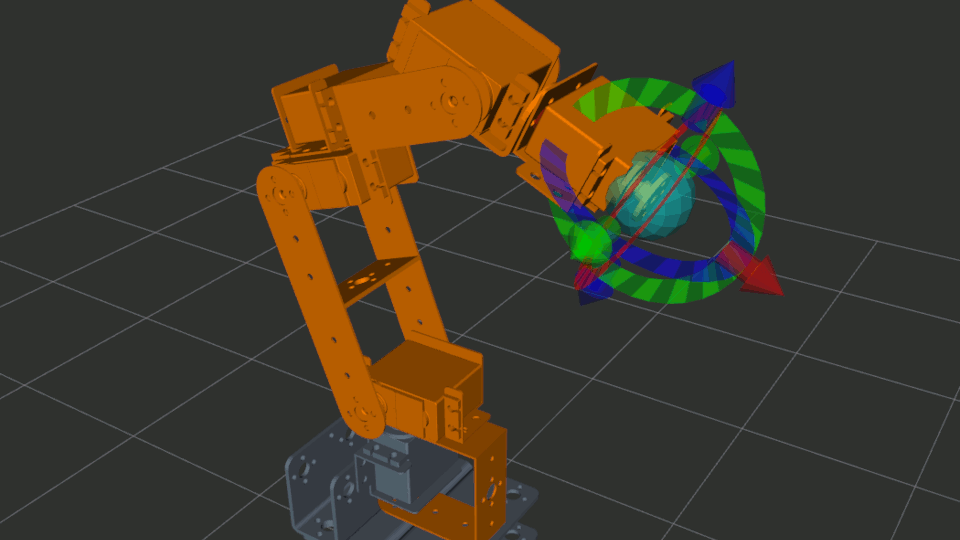
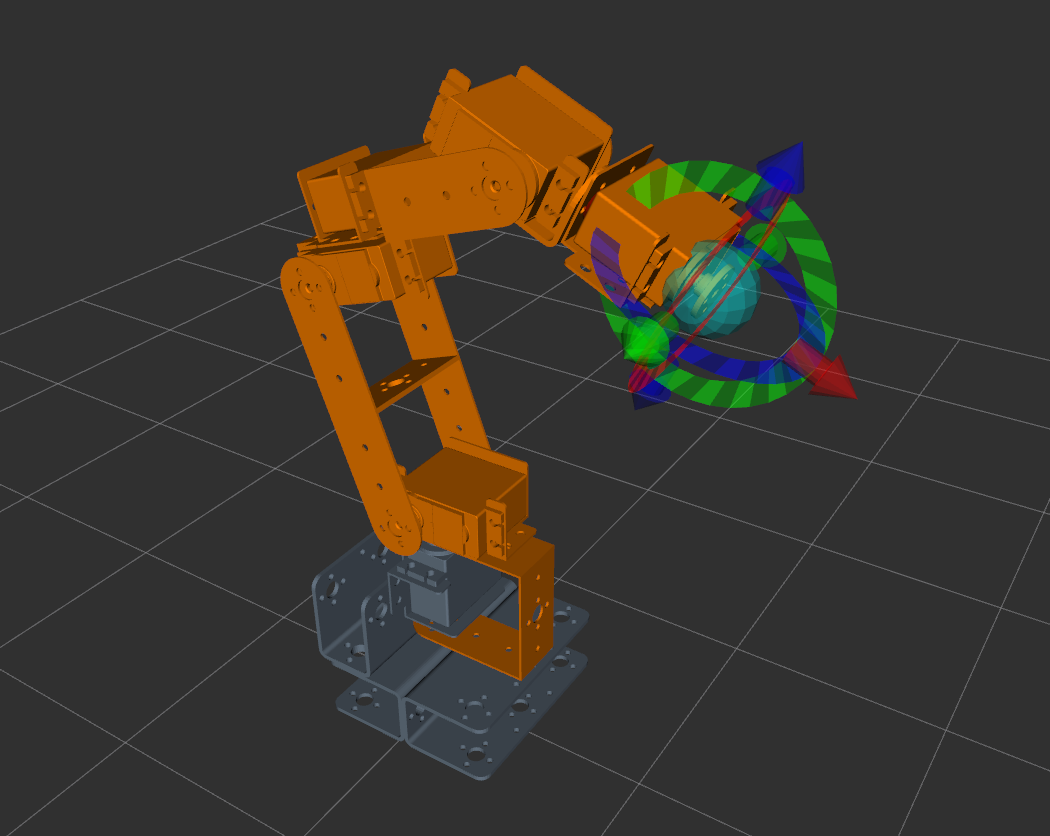
Servo Robot Arm

ROS driver for 6DOF Servo Robot Arm based on ROS-Industrial

Servo Robot Arm
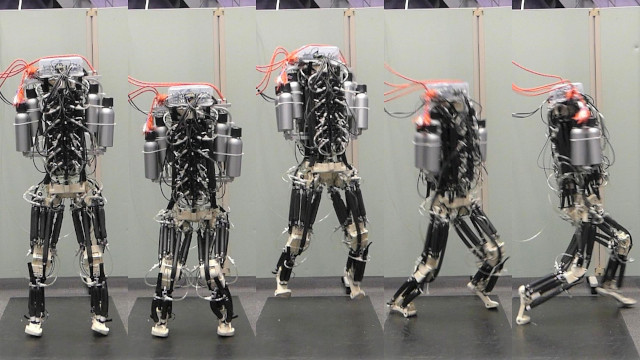
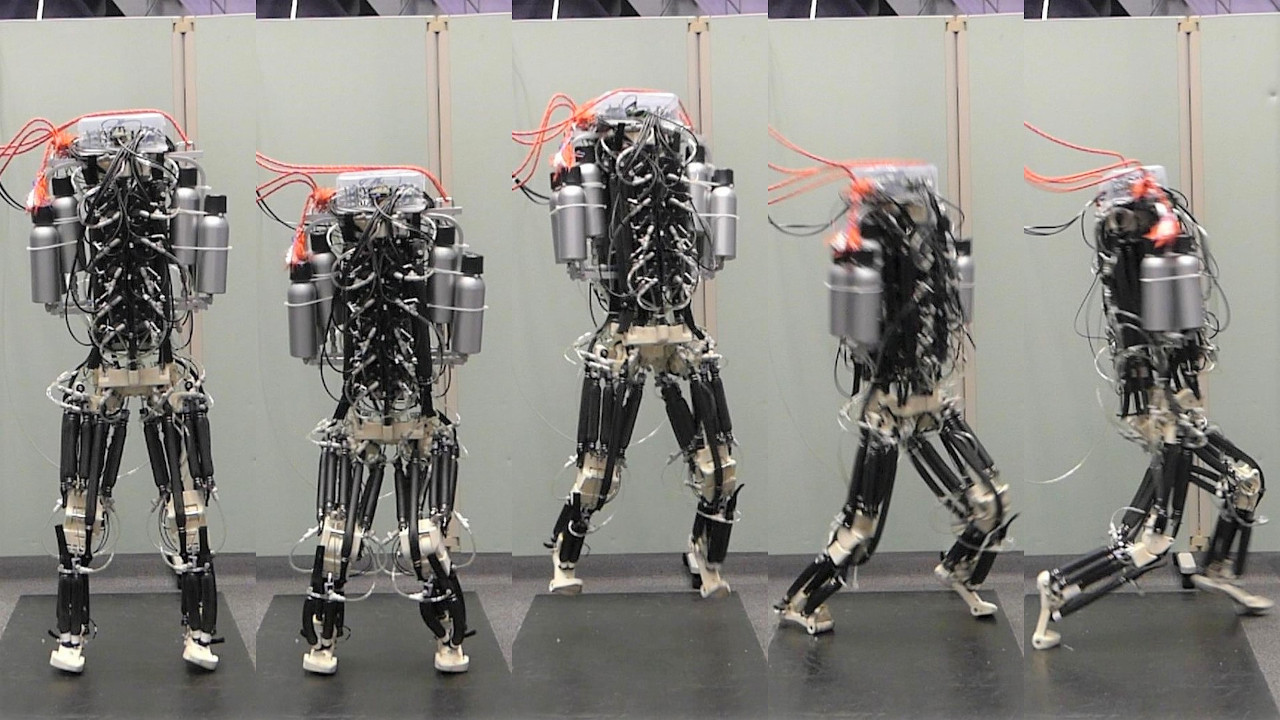
Musculoskeletal Robot

A bio-inspired humanoid robot using artificial muscles with agile locomotion skill

Jumping-Stepping musculoskeletal robot
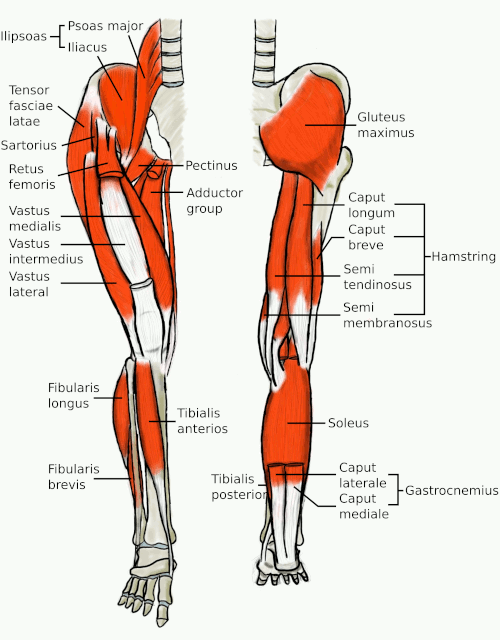
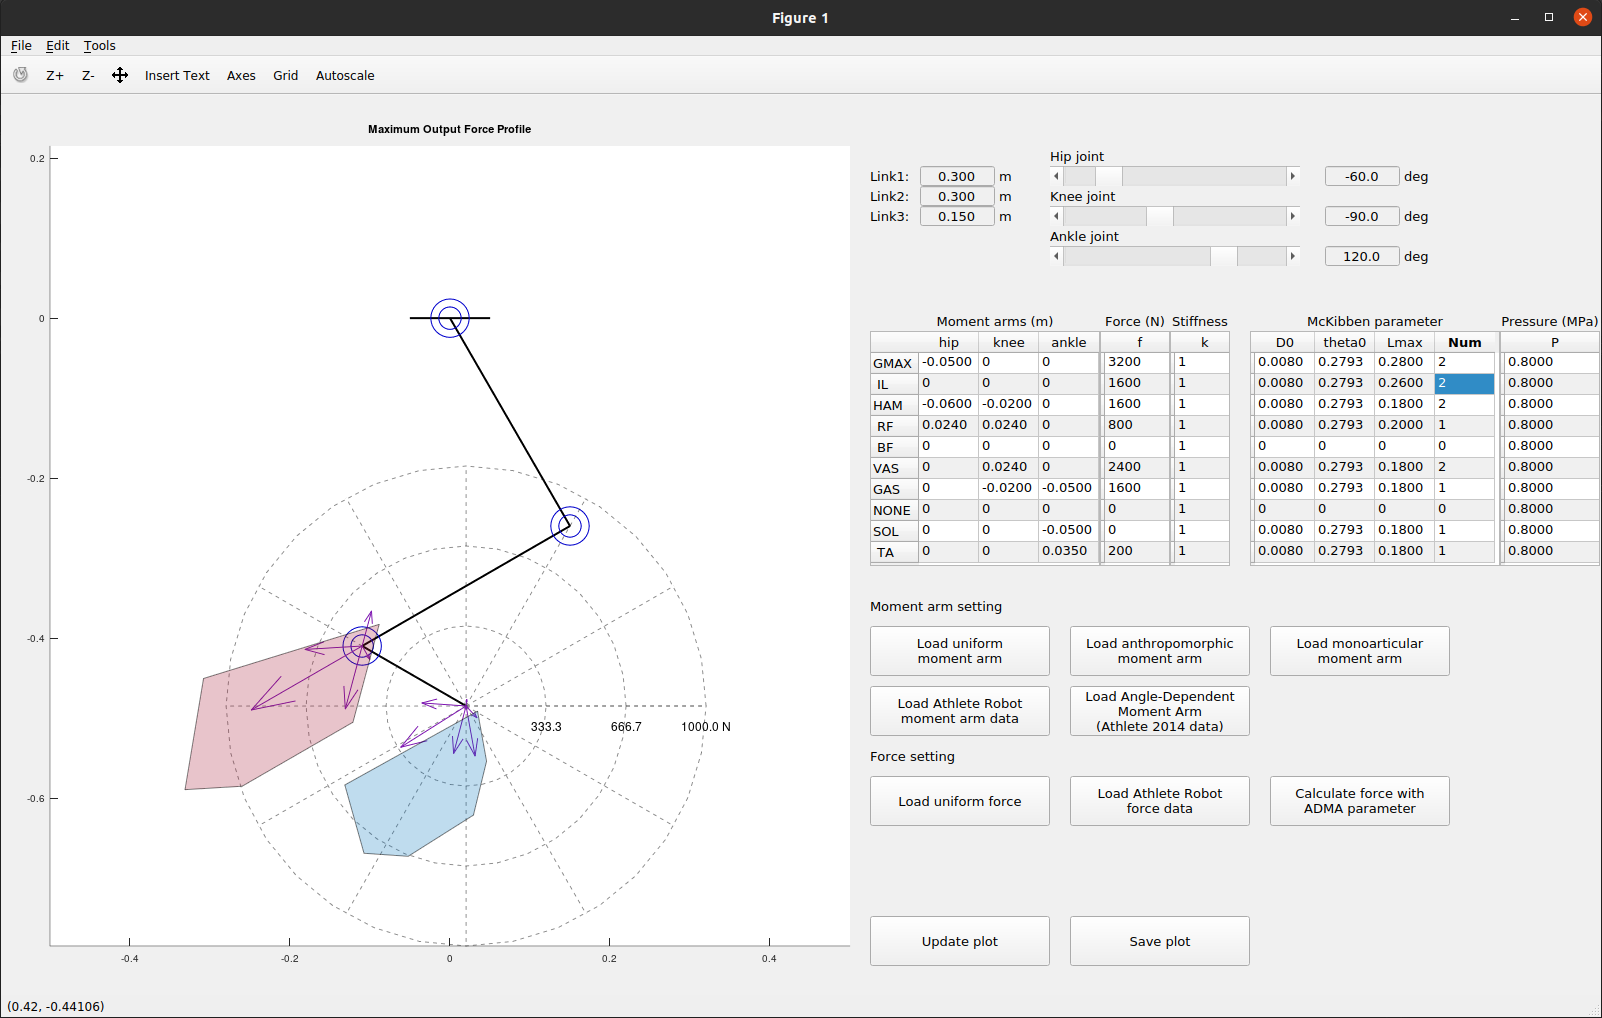
Musculoskeletal Force Analysis

Force analysis tool for a musculoskeletal system

Musculoskeletal Force Analysis
RoboSoccer

Faster response and improved performance using Anti-Windup Speed Control System

RoboSoccer
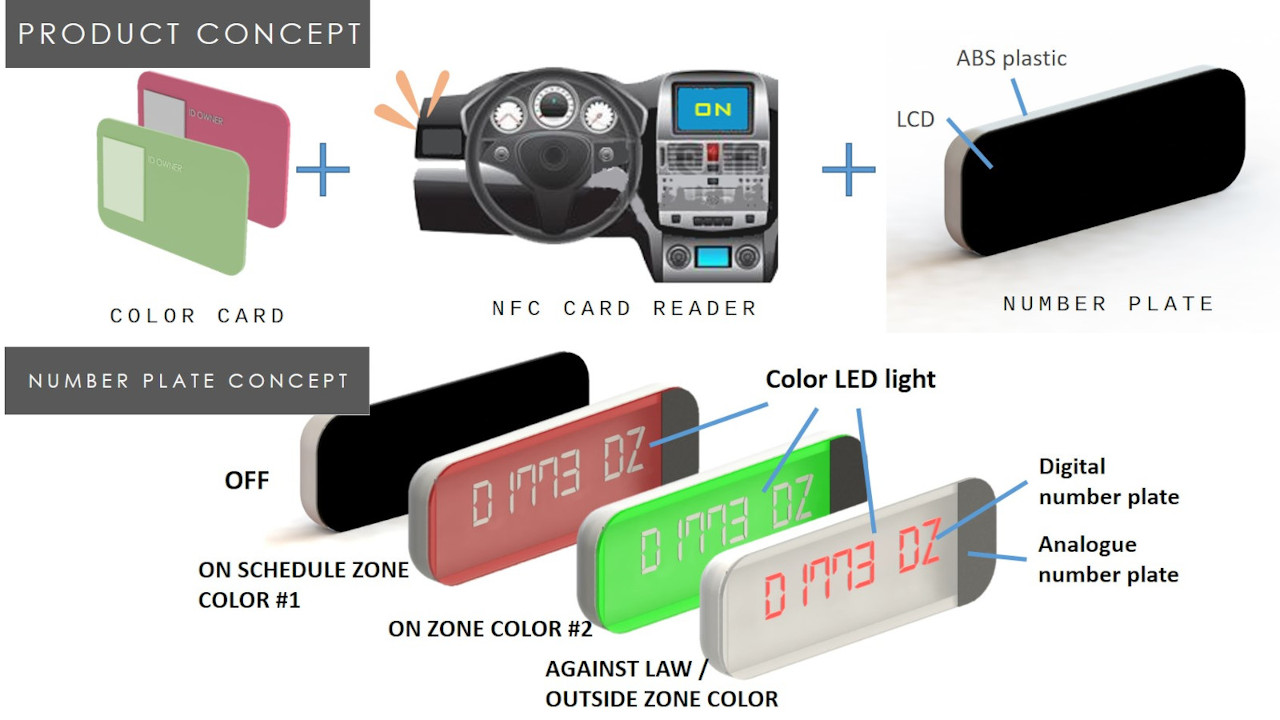
RFID-based Driving License Card

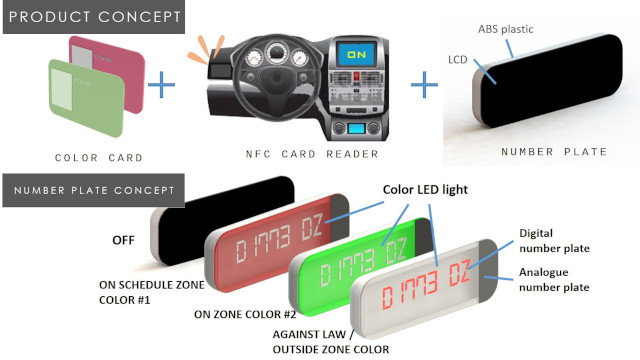
A conceptual design for traffic jam solution

ISCAPS design concept
Arduino Yun + Android

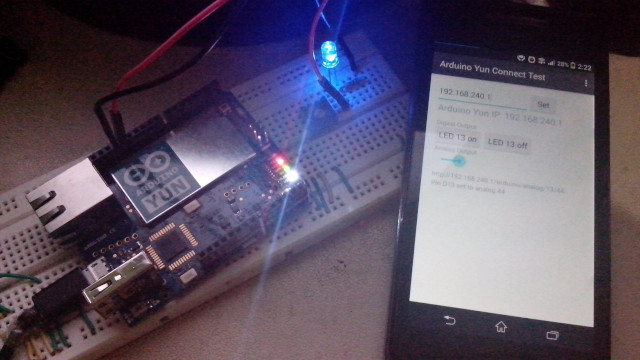
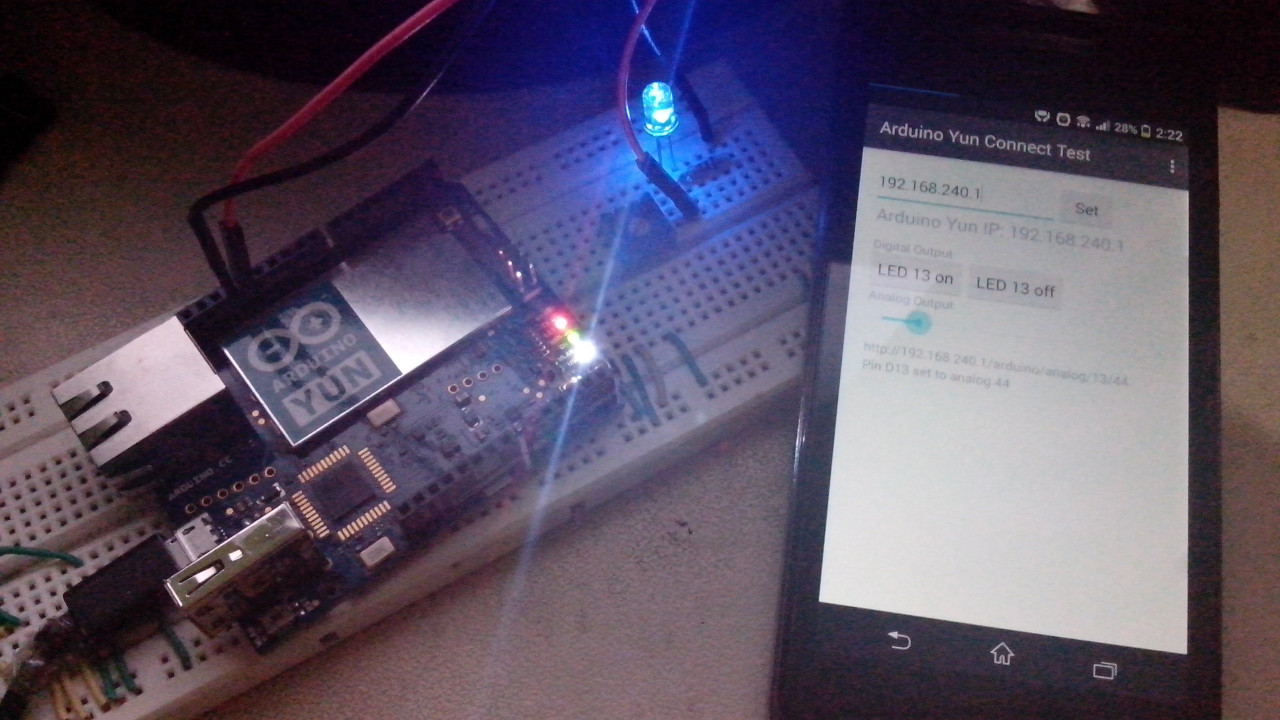
Interfacing Arduino Yun using an Android program over WiFi

Arduino Yun and Android

Blog

I wrote further details about my projects and other learning notes on my blog.

See my blog

Skills

Design
robot design icon actuator design icon PCB deisgn icon Web design icon
Platforms
ROS icon Docker icon
Arduino icon Raspberry BeagleBone icon
Programming languages
C++ icon Python icon Bash icon
Javascript icon HTML icon CSS icon